
One crank drives three eccentric cams that make a wooden bird nod, flap and lift its tail. Each rotating eccentric disc sets its follower height. Visible rods connect the followers to the bird, so changing the cam throw or phase changes the movement. Reuse your own material, or quote missing images and optional sound through PopNow before generation.
- Uses PopNow for
- Images · Music & voice
- Needs
- Python 3 · FFmpeg
The skill is free. Optional AI images, video and sound are quoted for your approval before generation. API-key calls use your separate API balance in USD; generation through ChatGPT or Claude connected via OAuth/MCP uses your website credits.
v1.0.0 · Updated Oct 25, 2026 · 3.0 MB · Use it for personal and client work; please don't resell or share the package.
What you get
An editable 6–12 second 720p MP4; the included example lasts 8 seconds and is silent.
Each rotating eccentric disc sets its follower height. Visible rods connect the followers to the bird, so changing the cam throw or phase changes the movement.
A six-frame contact sheet and render receipt with actual duration and hashes.
Good for
- Original creative shorts and visual motion studies
- Testing a reusable animation mechanism with your own inputs
Not for
- This is a constrained kinematic illustration, not a force, friction or manufacturing simulation. It does not export cutting plans or printable mechanical parts.
- Automatic feature-length films or unreviewed asset-rights claims
How to use it
You say
Use the PopNow skill "Wooden Cam Automaton" (wooden-cam-automaton) for this: Render the supplied 8-second example, then change one control to make a second version. Quote any missing assets before generating.
Then try
Use my own inputs and keep the project editable.
Show the changed frames and explain which setting caused the difference.
What to have ready
- A white-background atlas of carved torso, head, wing, tail, leg and joint cap; one empty workshop image and six normalized crop rectangles.
- part_boxes (six [left,top,right,bottom] rectangles), rpm (6–24), cam_throw (10–32), wing_phase (0–360 degrees)
- Python 3, Pillow, NumPy, FFmpeg and ffprobe
Similar skills
View all →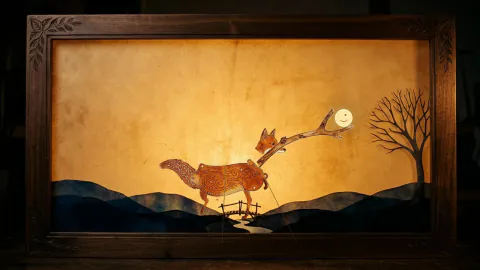 Video
Shadow Theatre Rescue
+25An articulated fox catches a falling moon and lifts it home on a warm shadow-theatre stage.
 Video
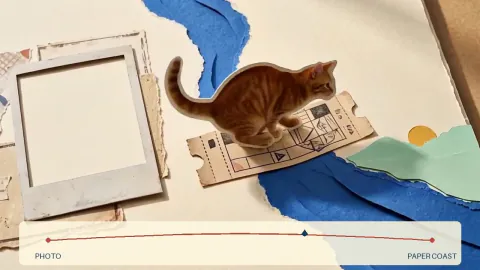
Photo Cutout Adventure
+25A pet or object escapes a photograph and hops across a paper landscape.
 Video
Light Painting Butterfly
+25A moving light draws a butterfly, which opens its wings and flies into the night with fading trails.
 Video
Kaleidoscope Motion Loop
+25Fold one rich texture into a rotating, mirrored rosette with a closed mathematical loop.
 Video
Sand Drawing Metamorphosis
+25Gold sand forms a shaded whale, is swept away, then gathers into a crane with spread wings.
 Video
ASCII Glitch Hype Film
+25Glyph-cell ASCII frames, tracking boxes and dot-matrix words cutting every tenth of a second to your logo.
 Video
Liquid Logo Reveal Sting
+25A glassy bead carries your mark, unreadable, then bursts and leaves the crisp lockup.
 Video
Cinematic Dark UI Teaser
+25Your UI adrift in a black void: a gliding camera, one sharp line of focus, a typed command, a glowing name.
 Video
Product Launch Film
+25A 20-40 s launch video from your URL or README, with ready-to-post copy and three aspect ratios.
 Video
ASMR Satisfying Video Maker
+25Slow-motion ASMR shorts like glass fruit cutting, with sound generated from the picture and a seamless loop.
 Video
Surreal Mind Collage
+25A hinged paper portrait opens onto three surreal thoughts, followed by playful detail shots.
 Video
Talking Object Drama Series
+25Vertical micro-drama episodes starring talking fruit or objects, with fixed character looks and voices.
 Video
Video Meme Maker
+25Original meme videos: an AI character acts out a known meme format, with real meme captions and sound.
 Video
History POV Video Maker
+25First-person 'you wake up in ancient Rome' shorts with a sourced facts sheet, narration and ambient sound.
 Video
Agent Crew Launch Video
+25Glossy helper characters on warm dotted paper, live phone tasks and a skill that hatches a brand-new helper.
 Video
AI Chatbot Demo Video
+25A narrated demo inside a dark chat app: switch on your integration, ask, get the result and a count-up.
 Video
AI Jingle Maker
+25An original jingle and audio logo kit: intro, outro, sting, loopable bed and voice tag, level-matched.
 Video
AI Music Video Maker
+25A beat-cut music video for your song: storyboard first, style-locked shots, 16:9 and 9:16.
 Video
Agentic Product Launch Film
+25A calm keynote-style launch film built from your product's real site and interface, cut on the beat.
 Video
Anamorphic Object Reveal
+25Scattered colored objects resolve into one image only from a precisely registered viewpoint.
 Video
Animated Checklist Product Demo
+25A paper-note checklist beside a phone screen; each box ticks the moment its step happens on screen.
 Video
Mobile App Promo Video
+25A 10-13 second app promo where seven product beats flow as one camera move, coded in HTML and GSAP.
 Video
Arcade Character Intro
+25An original character jumps into an arcade stage and lands in a title pose.
 Video
Before-and-After Comparison Launch Video
+25Near-black canvas, mono file names, one electric accent: your content as a still page, then as a film.
 Video
Blueprint Spec Promo Video
+25Your claim drawn on a near-black spec sheet: framed figures, hatching, leader lines and a title block.
 Video
Blueprint to Daydream
+25A drawn mechanical fish becomes a living watercolor creature and leaves the page.
 Video
Branching Engraving Growth
+25Draw a branching botanical structure over time and let extracted engraved leaves grow at its tips.
 Video
Changelog Explainer Video
+25Turn a real pull request into a 30-second film for people who will never read the diff.
 Video
One-Thread Chat Launch Video
+25One chat window on warm paper that never resets: ask about the wait, ask for the fix, watch it run.
 Video
Chronophoto Motion Study
+25Extract complete poses from a plain-background clip and compose a timed photographic movement study.
 Video
Claymation Food Loop
+25A playful clay pastry waves, then reverses back to its resting pose in a boomerang loop.
 Video
Depth Wiggle Parallax
+25Add a restrained depth wiggle to one image using editable, hand-authored depth regions.
 Video
Developer Tool Launch Reel
+25One prompt typed in four places, a beat-cut reel of real results, then your install command.
 Video
SaaS Product Video with Device Mockups
+25Your real app screen on a neutral device in a dark studio, then one live action and a bright reveal.
 Video
Warm Paper Editorial Launch Video
+25Oversized type on warm paper, one accent per frame, a lifted product card and an ink-black turn.
 Video
Explainer Motion Graphics Kit
+25122 code-built charts, diagrams, type and chapter effects; your agent picks one per line of your script.
 Video
Faceless Product Ad Maker
+25Hands-only unboxing, demo or orbit ads from your product photos, with several hook variants to test.
 Video
Complaint-to-Feature Launch Video
+25Open on the complaint your users keep posting, then prove the new feature makes it false.
 Video
Funny Problem-Solution Video
+25A small annoyance plays as a gag, polite requests pile up, then one orange pill becomes the fix.
 Video
Glass Caustic Message
+25Ripples scatter a short light message, then settle until the projected letters become readable.
 Video
Halftone Canvas Launch Video
+25A launch film on one living dot canvas that moves a beat before every line of text.
 Video
Hand-Drawn Infographic Video
+25Felt-tip panels on one long poster, a drawn route the camera follows, then a pull-back to the whole sheet.
 Video
Kinetic Scrapbook Story
+25A ticket opens into a map and photos arrive as events along a visible route.
 Video
Living Still Cinemagraph
+25Keep a courtyard still while water moves inside a hand-drawn, softly feathered region.
 Video
Lyric Video Maker
+25Song and lyrics in, a synced lyric video out in 16:9 and 9:16, words lighting up as they are sung.
 Video
Miniature Object Odyssey
+25An everyday object sails through a miniature world with a clear departure and arrival.
 Video
Moiré Wave Motion
+25Create slowly traveling optical waves from two finely drawn, independently warped stripe fields.
 Video
Moodboard Reel Video
+25A 9:16 moodboard reel: three photo boards hard-cut on the beat, then snap into one share board.
 Video
Multi-Style Keynote Launch Video
+25Each capability in its own world: a blue chart, a cream serif page, a dark light field, a poster grid.
 Video
Multilingual Launch Video
+25Your product name holds still while each language rolls in, in its own script, voiced and captioned.
 Video
Narrated Explainer Video
+25A 45-120 second explainer with voiceover and word-synced captions, in collage, whiteboard or data style.
 Video
Open World City Trailer
+25A fictional city becomes a short discoverable world with locations and a simple travel objective.
 Video
Origami Creature Awakening
+25A folded paper creature wakes up, stretches and takes its first step or flight.
 Video
Paper-Cut Science Animation
+25Shadow-box paper layers, a cut-paper Sun and Moon, labels swinging on strings: one science idea, narrated.
 Video
Paper Portal Reveal
+25A tear in an ordinary paper surface opens into a tiny moving landscape.
 Video
Partnership Announcement Video
+25A presenter in a bordered window, two logos on one card, a typed three-step setup, verbs rolling on cue.
 Video
Pinscreen Memory Sculpture
+25Your image rises from a field of individual metallic pins, then settles back into the board.
 Video
Pixel Art Promo Video
+25A retro pixel-art film about your product, drawn frame by frame from your link, pitch or story.
 Video
Pixel Sort Ribbon Film
+25Stretch a photograph into luminous pixel ribbons by sorting real luminance-selected pixel runs.
 Video
Plush Character Launch Video
+25Felt plush characters ride cursors and build your promo live in a team editor, every cut on the beat.
 Video
Podcast Clip Maker
+25Finds the best moments in an episode and turns them into captioned vertical and square podcast clips.
 Video
Reaction Diffusion Organism
+25Grow intricate coral-like forms with a deterministic, editable reaction-diffusion simulation.
 Video
Recursive Window Journey
+25Travel through three nested worlds in one continuous, precisely aligned camera journey.
 Video
Slit-Scan Time Ribbon
+25Stretch real movement into flowing ribbons by giving each image strip a different source time.
 Video
Silence-to-Sound Reveal Promo
+25A button pressed three times in total silence, then the same shot again with sound, then with music.
 Video
Square UI Morph Promo
+25On warm paper a button stretches into a prompt card, then the view zooms out to a wall of sessions.
 Video
Paper Storybook Animation
+25A picture book that moves: felt-and-clay cut-outs, layered paper hills and words that pop on one by one.
 Video
Testimonial Video Maker
+25Portrait plates with a raised quote card on warm ruled paper, one teal accent, a calm crossfade per customer.
 Video
Text Behind Person Title
+25A giant headline punches in behind the person on camera, then owns the frame after a clean cut.
 Video
Text Message Story Video
+25Vertical chat story videos: messages pop in, dots show typing, and sounds land on every bubble.
 Video
Material Texture Type Promo
+25Headline letters cut from terrazzo, brick and steel, swapping surface every 3 frames over a warm moodboard.
 Video
TikTok Slideshow Maker
+25Matching 9:16 slides with exact text in the safe zone, as a TikTok photo set and a video with music.
 Video
Triangular Photo Shatter
+25Break a photograph into textured triangular pieces, then rebuild the exact original image.
 Video
Video Chapter Title Cards
+25Stamp-in chapter cards for long videos, numbered from one list, with the timestamp list for your description.
 Video
Cinematic Sound Effects for Video
+25Sound design for silent or poorly recorded videos: synced effects per shot, ambience, score and a clean mix.
 Video
Whiteboard Animation Video
+25A marker pen draws the whole lesson on one board, erases the myth, then pulls back to the finished board.
 Video
Woven Photo Transition
+25Interlace two photographs as alternating paper ribbons with visible over-and-under crossings.
 Video
YouTube End Card & Intro Maker
+25A matching channel intro, a 20 second YouTube end card and stream screens, laid out around YouTube's elements.
 Video
Zoetrope Loop Theatre
+25A ring of illustrated bird poses turns in an antique workshop, then resolves into a repeating wingbeat.
 Video
Animated Timeline Video
+25A dated, sourced sequence with measured date gaps and a milestone narration.
 Video
Annotated Screen Tutorial
+25A sourced screen walkthrough with normalized focus regions and redaction checks.
 Video
Budget Breakdown Video
+25A reconciled cost film with recurring costs, one-off costs and contingency.
 Video
Capacity Planning Video
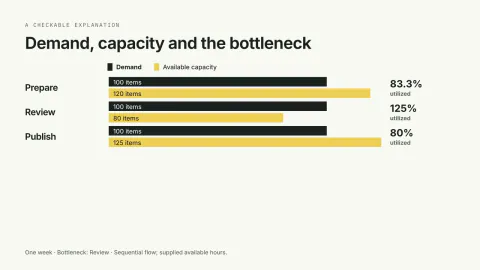
+25A demand-versus-capacity film with utilization and bottleneck calculations.
 Video
Decision Matrix Video
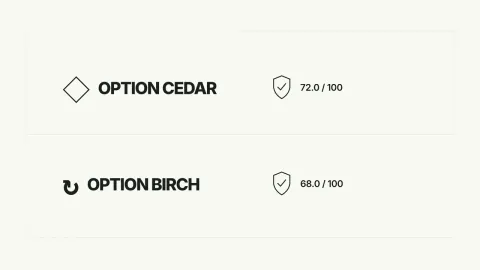
+25A weighted decision film with cost direction, tie handling and sensitivity.
 Video
Document Summary Video
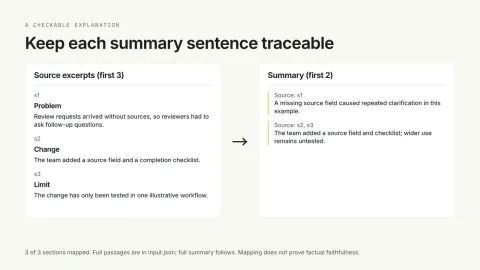
+25A traceable document summary with paragraph mapping and coverage limits.
 Video
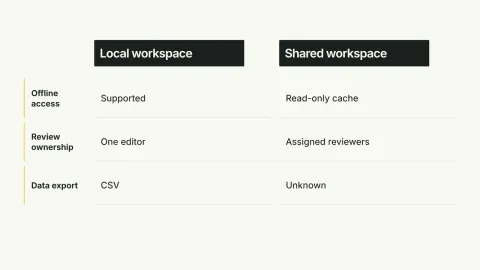
Equation Explainer Video
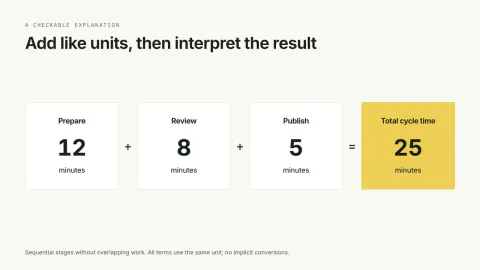
+25An additive equation film with units, arithmetic and a reproducible result.
 Video
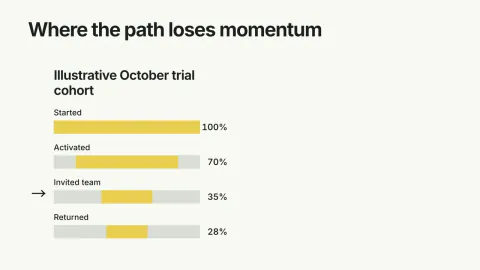
Feature Comparison Video
+25A dated feature matrix with evidence, unknown states and audience tradeoffs.
 Video
Funnel Drop-off Video
+25A cohort-based funnel story with step conversion and largest-loss analysis.
 Video
AI Assets for HyperFrames
+25Hero stills, B-roll, music beds and voiceover for HyperFrames videos, quoted first and filed in assets/.
 Video
Incident Postmortem Video
+25A blameless incident narrative with impact, evidence and owned follow-ups.
 Video
Keyboard Shortcut Tutorial
+25A platform-specific shortcut film with menu fallback and before/after evidence.
 Video
Timed Kinetic Captions
+25Word-timed captions with reading-speed checks, safe zones and editable subtitles.
 Video
Knowledge Base Walkthrough
+25A permission-aware navigation film with breadcrumbs and declared search results.
 Video
Meeting Agenda Video
+25A timeboxed meeting brief with owners, decisions and an overflow check.
 Video
Mind Map Animation
+25A verified concept tree with bounded depth and explicit relationship labels.
 Video
Mobile App Tutorial Video
+25A touch-target walkthrough with exact tap order, safe zones and expected states.
 Video
Onboarding Checklist Video
+25A role-specific onboarding sequence with evidence-based completion gates.
 Video
Org Chart Animation
+25A validated reporting tree with role scope and vacant positions clearly marked.
 Video
Pricing Comparison Video
+25A comparable total-cost video with seats, periods, setup fees and scope.
 Video
Process Cycle Animation
+25A closed operating cycle with owners, handoff criteria and a failure exit.
 Video
Prompt Evaluation Video
+25A controlled prompt comparison with paired scores, failures and reproducible settings.
 Video
Quote Highlight Video
+25An exact quotation with attribution, source locator and permission record.
 Video
Radar Profile Video
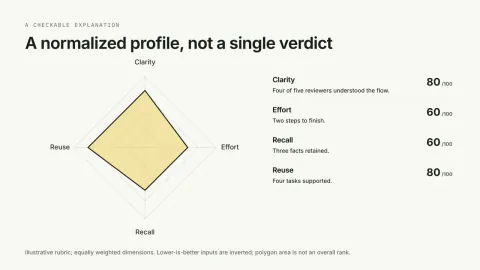
+25A score profile with explicit scale direction and rejection of missing scores.
 Video
Ranked List Video
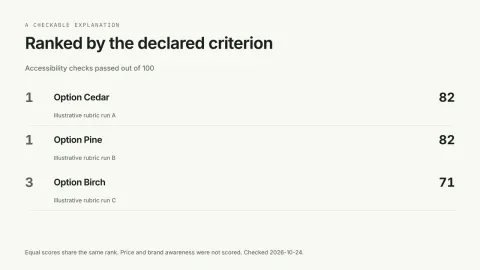
+25A transparent ranking film with declared scores, ties and exclusions.
 Video
Research Evidence Video
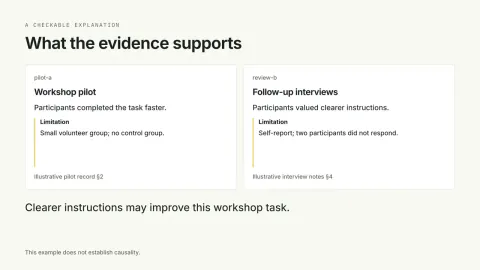
+25An evidence-led explanation with study limits and claim-to-source mapping.
 Video
Roadmap Update Video
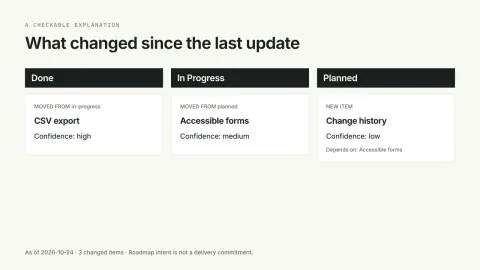
+25A change-focused roadmap with dependencies and confidence labels.
 Video
ROI Explainer Video
+25An auditable return calculation, payback estimate and assumptions film.
 Video
Supply Chain Explainer
+25A material-flow film with lead time, yield and exception notes.
 Video
Survey Results Video
+25A denominator-aware survey film with exact counts, rounding and limitations.
 Video
Swimlane Process Video
+25An actor-by-actor handoff film with waiting time and ownership checks.
 Video
Terminology Explainer Video
+25A sourced definition with a misconception, example, counterexample and scope.


Questions
Are the cams actually connected to the bird?
Yes. Follower positions are calculated from the eccentric discs, and the bird joints use those positions. The connecting rods remain visible.
Can I use this as an engineering design?
No. It demonstrates motion relationships. Clearances, stresses, material limits and manufacturability are not calculated.
What does the local renderer check?
It checks input ranges, required images, frame size and encoded duration. The self-check also tests a changed input and a rejected invalid case. You still need to watch the result.